About
Profile
Engineering robotic systems from mechanism to experiment
I am a mechatronics engineer and robotics researcher at RoboticsLab, Universidad Carlos III de Madrid. I work as Scientific and Technical Activities Staff within the SRAR project while completing an M.Sc. in Robotics and Automation. My work sits between mechanical design, control engineering, biomedical applications, and experimental research.
I am currently developing tendon-based soft robotic actuation using Shape Memory Alloy wires. The objective is to turn a compact but thermally complex actuator into a controlled, repeatable mechanism suitable for early-stage ankle rehabilitation research.
I am also registered in Peru’s national science and technology registry (RENACYT P0153371) and serve as an invited scientific reviewer for IEEE Latin America Transactions.
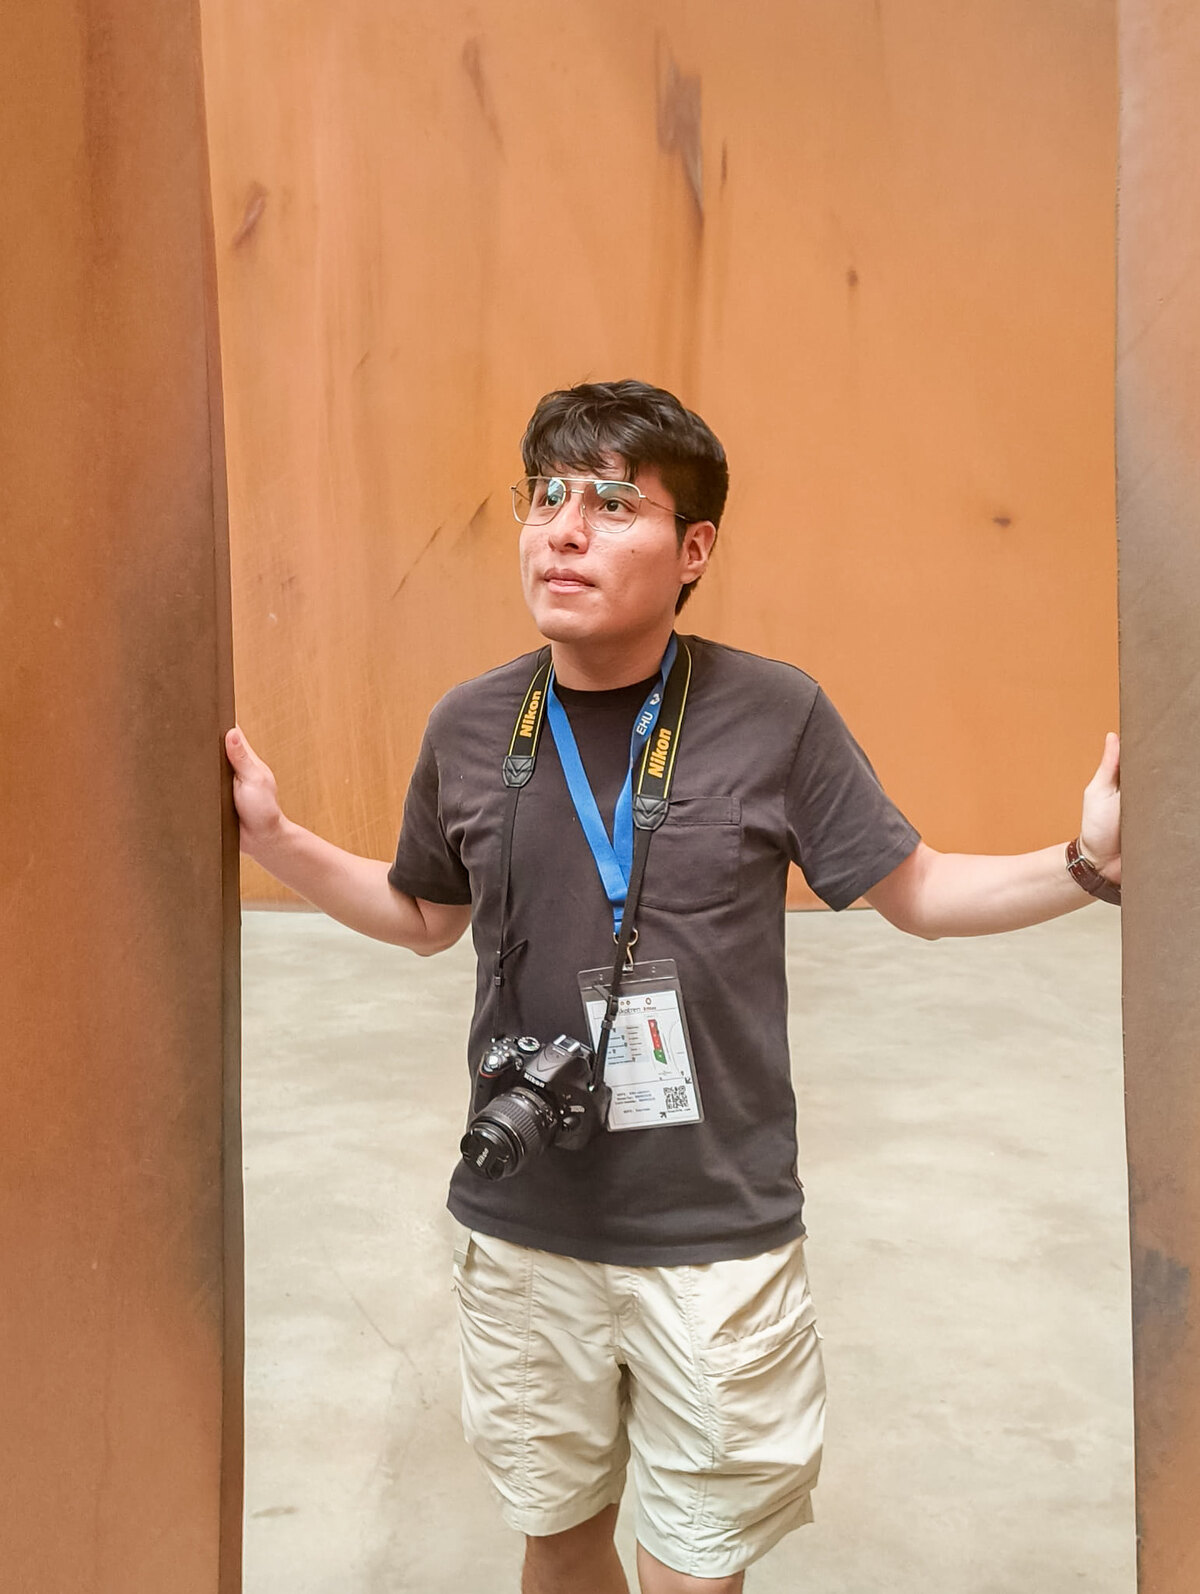
Bilbao · June 2026
Current focus
My master’s research investigates a modular ankle rehabilitation device based on antagonistic SMA actuation. Rather than assisting gait, the platform targets controlled dorsiflexion and plantarflexion exercises for seated or bed-based early rehabilitation.
The work covers the complete mechatronic chain: mechanism design, tendon transmission, electronic activation, sensor integration, state-based control, indirect thermal supervision, and experimental validation. I am particularly interested in methods that make difficult actuators more dependable through careful system architecture rather than treating control as an isolated layer.
This research is conducted at RoboticsLab as part of Soft Robotics for Ankle Rehabilitation (SRAR), grant PID2023-149141OB-I00.
Research trajectory
2025–present · RoboticsLab and the SRAR project
Researcher in the Exoskeletons Laboratory at UC3M, developing SMA-based ankle rehabilitation systems and their experimental validation. Since September 2025, I have held a Scientific and Technical Activities Staff position while continuing this research and my master’s thesis.
2024–2026 · Robotics and Automation at UC3M
M.Sc. studies in robotics, control, soft robotics, model-based design, and experimental validation. Current thesis work focuses on tendon-based SMA actuation for ankle rehabilitation.
2023 · Peer-reviewed biomedical research
Published preliminary studies on robot-assisted 3D-ultrasound breast biopsy and deep-learning identification of epileptic seizures from EEG signals in IEEE Latin America Transactions.
2022 · Professional title in Mechatronics Engineering
Completed a thesis on the modeling and simulation of a clinical robot assisted by 3D ultrasound for percutaneous breast-biopsy needle guidance at Universidad Nacional de Trujillo.
2020 · Engineering during the COVID-19 emergency
Contributed to low-cost initiatives involving ventilator restoration, infrared thermometry, and automated disinfection systems in Peru.
How I work
Build the whole system
I prefer problems where mechanics, electronics, sensing, and control must work together. A strong result should survive contact with the physical prototype.
Validate experimentally
I value repeatable tests, transparent metrics, failure analysis, and long-duration experiments that expose behavior hidden by short demonstrations.
Document what is learned
Quarto, LaTeX, MATLAB, Python, and structured technical writing are part of the research process, not tasks added after the engineering is finished.
Technical interests
Beyond the laboratory
I maintain La Tercera Fundación, a Spanish-first knowledge archive where I write about robotics, academic tools, reproducible workflows, and literature. Photography and visual communication also influence how I document technical work and how this website is designed.